

ALFRENSIA · AI & ROBOTICS
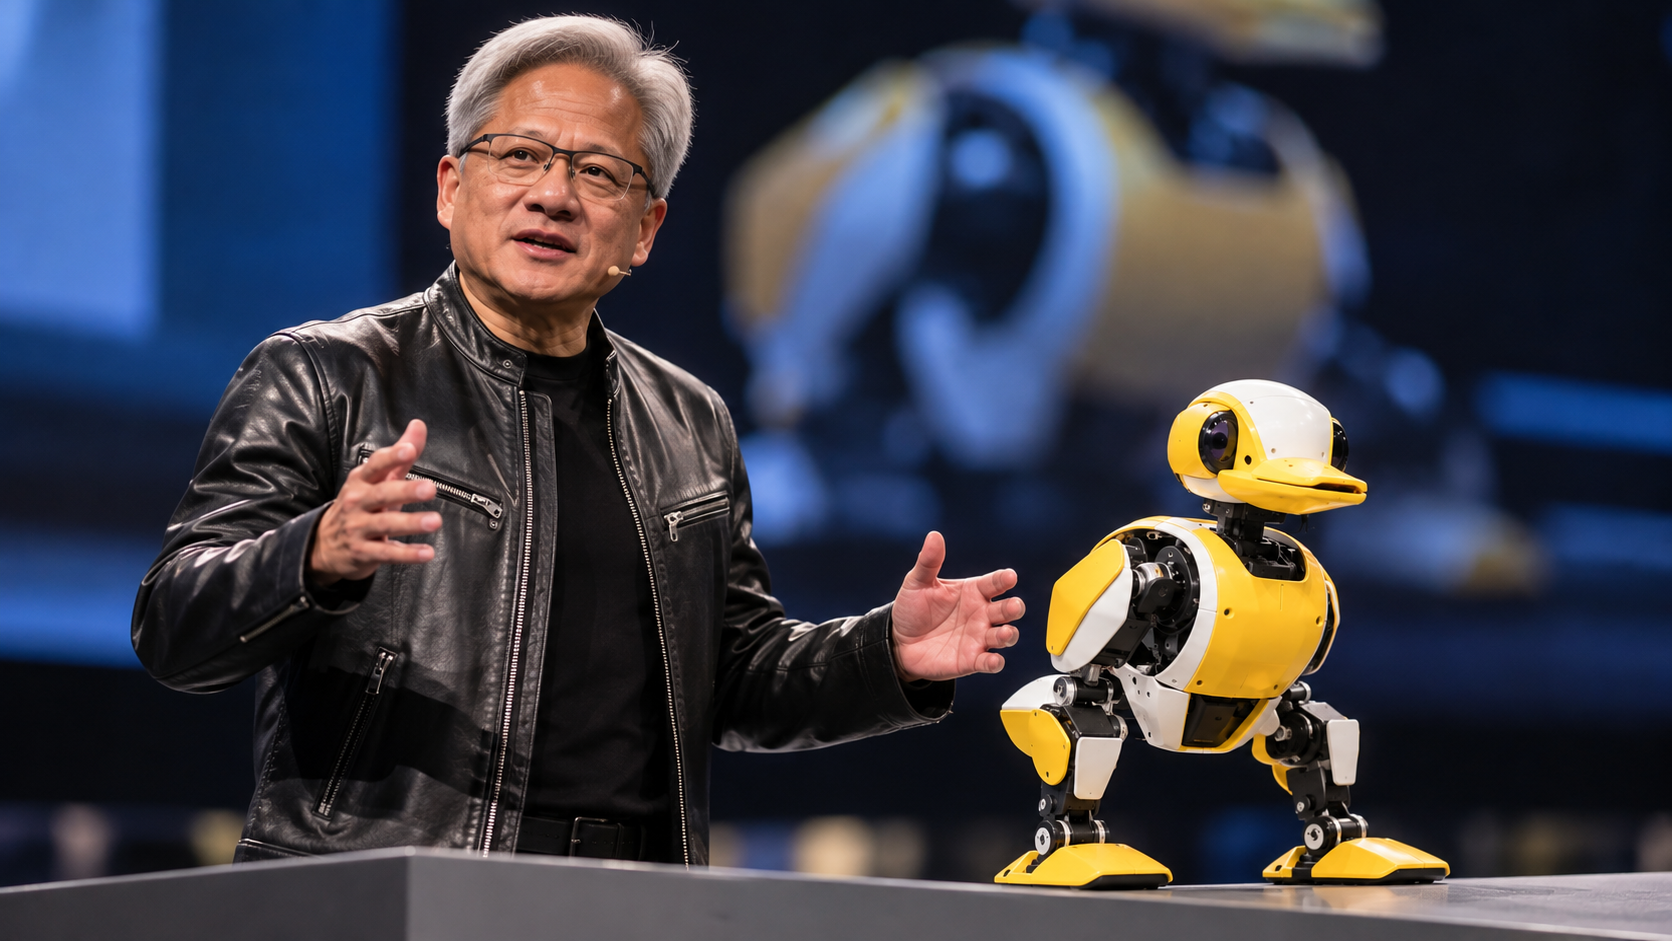
“Can you sit down? Stand up. Take a nap.” At NVIDIA’s GTC Berlin keynote on October 21, 2026, CEO Jensen Huang addressed a group of tiny duck-shaped robots, asking them to follow simple commands and later calling for a somersault. The funny stage moment also illustrated a much more serious idea: robotics depends on a stack of AI models, simulation, training and real-world testing—not a single magic command.
NVIDIA’s official recap says AI agents running on NVIDIA RTX Spark were used in a workflow to train Hugging Face’s Microduck robot with NVIDIA Isaac Lab, Hermes Agent and Nemotron 3.5 Bolt 74B. Reuters independently described the stage robots as small bipedal machines developed by Pollen Robotics with Hugging Face. The important detail is that the demonstration involved several stages and computing environments.
What this article does—and does not—claim: NVIDIA’s demonstration connects RTX Spark-based agents with a robot-training workflow. It does not mean every part of the robot’s training ran on RTX Spark, or that a robot can learn any new skill instantly just by receiving a spoken instruction.
1. Meet Microduck: the tiny robot that stole the show
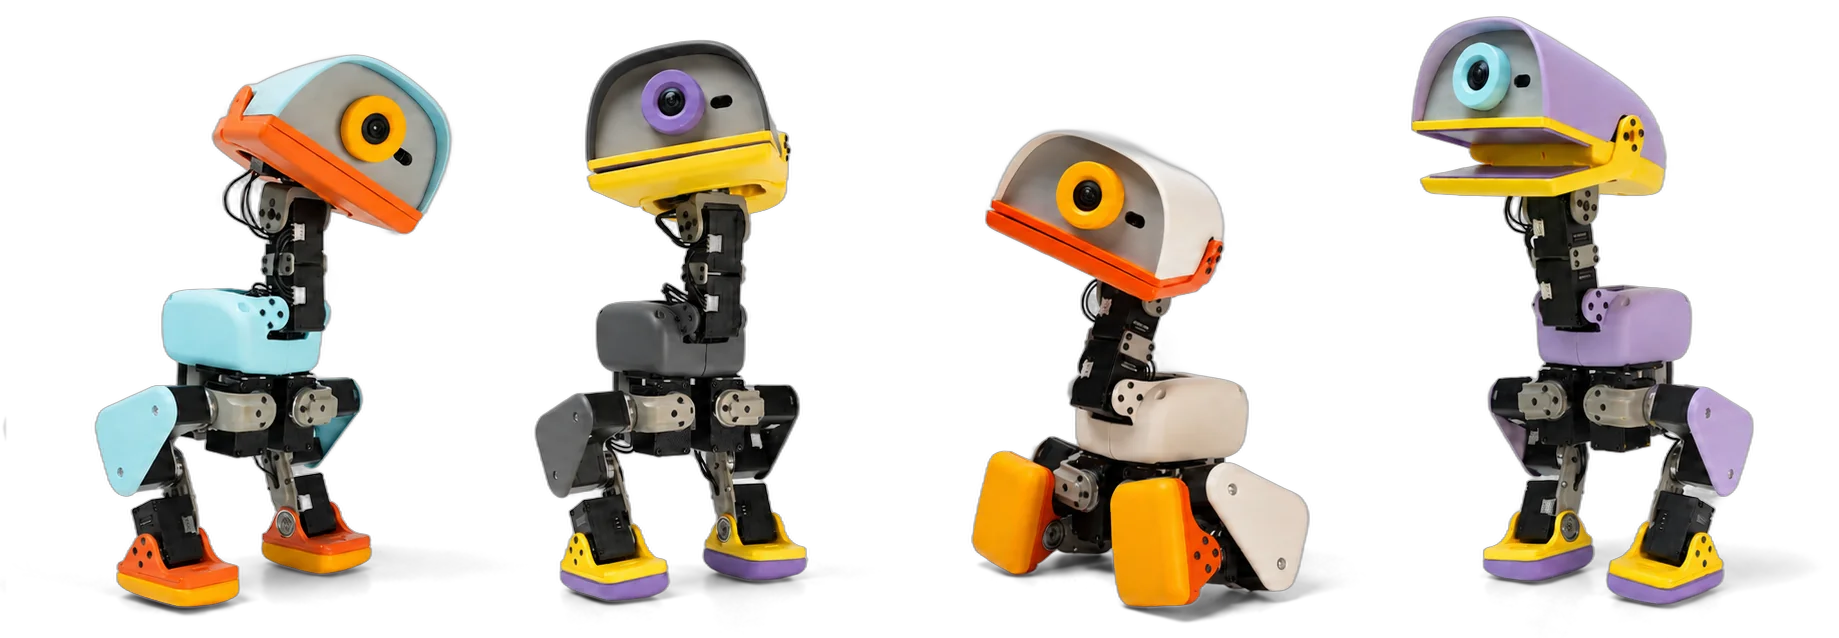
The Microducks are small, duck-shaped bipedal robots developed by Pollen Robotics, the robotics team at Hugging Face. Pollen lists the robot at 25 cm tall with 15 motors, a front camera, LiDAR and two IMUs. During the keynote, Huang asked them to walk, sit, stand and take a nap. The moment was charming partly because the robots did not all react perfectly. Reuters reported that several toppled over when asked to take a nap, while another needed more prompting.
That imperfect response is useful context, not a sign that the entire approach failed. Physical robots must deal with balance, cameras, joint movement, contact with the ground and uncertainty in their surroundings. A command that sounds simple to a person can require perception, planning and motion control working together.
2. What role did NVIDIA RTX Spark play?
RTX Spark is NVIDIA’s class of Windows PCs built for local AI, creative workloads and gaming. NVIDIA lists configurations with up to 128GB of unified memory and up to one petaflop of FP4 AI compute. In this demonstration, NVIDIA says AI agents running on RTX Spark helped coordinate parts of the Microduck training workflow.
Think of the system as a development computer for working with AI tools and robotics software. The local machine can help run an agent, prepare a scene, coordinate tools, or evaluate a candidate behavior. These tasks are distinct from running large-scale training simulations in the cloud, which Huang also described during the keynote.
3. How the AI-to-robot workflow fits together
NVIDIA’s account names Hermes Agent, Nemotron 3.5 Bolt 74B and Isaac Lab. Huang’s keynote explanation also described using Isaac Sim and Omniverse to assemble a digital twin, simulate the robot’s movement and cameras, and then evaluate a learned policy before deploying it to the physical robot.
Keep the layers separate: an AI agent can call tools and coordinate work; a simulation reproduces a robot and environment digitally; a learned policy determines actions within its intended control system. They can work together, but they are not interchangeable.
4. Simulation, training and deployment are different steps
| Stage | What happens | Why it matters |
|---|---|---|
| Simulation | A virtual robot interacts with a modeled environment. | Developers can test many situations without every trial happening physically. |
| Training | A learning system improves a policy using its training setup and feedback. | Repeated attempts can help the policy perform a defined task more reliably. |
| Evaluation | The candidate policy is tested against selected scenarios and failure cases. | Developers need evidence that behavior is safe and robust enough for the next step. |
| Deployment | A validated policy is transferred to the physical robot and tested on the hardware. | Real surfaces, sensors, timing and mechanical limits can differ from simulation. |
Simulation can speed up development, but it is not a guarantee of perfect real-world performance. Differences between simulated physics and the real robot, sensor noise, hardware variation and unexpected obstacles all matter. Good robotics workflows include evaluation and real-world checks rather than treating one successful demo as universal proof.
5. What does this mean for PC enthusiasts and AI developers?
The wider trend is that powerful local computers are becoming useful for more than games and conventional creative applications. Developers may run language models, agents and development tools on their own machine, while connecting to cloud resources when a workload requires much more compute. The right balance depends on privacy needs, model size, performance targets, power, software compatibility and budget.
RTX Spark is not the same purchasing decision as a typical GeForce gaming PC. Some users mainly need high gaming frame rates; others need memory capacity, a supported AI software stack or access to workstation and cloud tools. Choose hardware from the applications and requirements you actually plan to use—not from one exciting robot clip.
For a general desktop build, Alfrensia’s existing guides can help you understand local AI hardware requirements and graphics-card power-supply planning. These are general PC buying guides, not claims that a gaming GPU is equivalent to RTX Spark.
6. Quick answers
Did Jensen really tell the robots to take a nap?
Yes. During the October 21 GTC Berlin keynote, he asked the Microducks to sit down, stand up and take a nap. Reuters also reported on the uneven response and the later somersault request.
Did RTX Spark perform all the robot training?
No such claim should be made. NVIDIA says agents running on RTX Spark were used in the training workflow. Huang’s explanation also described training thousands of simulated Microducks in the cloud, then downloading and evaluating a policy before deploying it to the physical robot.
What is Isaac Lab?
Isaac Lab is NVIDIA’s open-source framework for robot learning and simulation workflows. It belongs to the robotics development side of the story, distinct from the computer hardware itself.
Can an ordinary gaming PC train a robot like this?
It depends on the software, workload, model, memory, GPU support and scale of the task. A gaming PC can be useful for some AI experiments, but it should not be assumed to reproduce this complete workflow without checking requirements.
Sources and further reading
- NVIDIA Blog — Bringing the Spark to Europe (October 21, 2026)
- NVIDIA — GTC Berlin 2026 keynote recap
- NVIDIA Isaac Lab — official framework and documentation
- Pollen Robotics — official Microduck page
- NVIDIA GTC Berlin keynote — event and on-demand video
المؤسسة الفرنسية للكمبيوتر · الذكاء الاصطناعي والروبوتات
«ممكن تقعد؟ قوم. خد قيلولة». خلال كلمة NVIDIA في مؤتمر GTC Berlin يوم 21 أكتوبر 2026، وجّه الرئيس التنفيذي جنسن هوانج أوامر بسيطة لمجموعة من الروبوتات الصغيرة اللي شكلها بط، وطلب منها تقعد وتقوم وتاخد قيلولة، وبعدها طلب منها تعمل شقلبة. الموقف كان طريف، لكنه كمان بيشرح فكرة أهم: الروبوتات بتعتمد على منظومة من نماذج الذكاء الاصطناعي والمحاكاة والتدريب والاختبار الحقيقي، مش مجرد أمر واحد سحري.
ملخص NVIDIA الرسمي بيقول إن وكلاء ذكاء اصطناعي شغالين على NVIDIA RTX Spark استخدموا ضمن سير عمل لتدريب روبوت Microduck التابع لمشروع Hugging Face، بالاعتماد على NVIDIA Isaac Lab وHermes Agent وNemotron 3.5 Bolt 74B. ووصفت Reuters الروبوتات اللي ظهرت على المسرح بأنها روبوتات صغيرة ثنائية الأرجل على شكل بط، طوّرتها Pollen Robotics بالتعاون مع Hugging Face. المهم إن العرض كان جزءًا من منظومة فيها مراحل وأدوات وموارد حوسبة مختلفة.
المقال بيقول إيه وما بيقولش إيه؟ عرض NVIDIA بيربط بين وكلاء ذكاء اصطناعي على RTX Spark وسير عمل لتدريب روبوت. ده مش معناه إن كل التدريب حصل على RTX Spark، ولا إن الروبوت يقدر يتعلم أي مهارة فورًا بمجرد ما يسمع أمرًا صوتيًا.
1. نتعرف على Microduck: الروبوت الصغير اللي خطف الأضواء
Microduck عبارة عن روبوت صغير على شكل بط وبيمشي على رجلين، بتطوره Pollen Robotics، فريق الروبوتات التابع لـ Hugging Face؛ والمواصفات المنشورة بتذكر إن طوله 25 سم وفيه 15 موتور وكاميرا أمامية وLiDAR وحساسين IMU. خلال الكلمة، جنسن هوانج طلب منه يمشي ويقعد ويقوم وياخد قيلولة. والجزء الطريف إن الاستجابة ما كانتش مثالية عند كل الروبوتات. Reuters ذكرت إن بعضهم وقع لما طلب منهم ياخدوا قيلولة، وروبوت تاني احتاج تكرار التعليمات.
الاستجابة غير المثالية دي سياق مهم، لكنها مش دليل على فشل الفكرة كلها. الروبوت الحقيقي لازم يتعامل مع التوازن والكاميرات وحركة المفاصل وملامسة الأرض وعدم اليقين في البيئة المحيطة. أمر بسيط بالنسبة للإنسان ممكن يحتاج تنسيق بين الإدراك والتخطيط والتحكم في الحركة.
2. إيه دور NVIDIA RTX Spark؟
RTX Spark هي فئة من أجهزة الكمبيوتر بنظام Windows من NVIDIA، موجهة لتشغيل الذكاء الاصطناعي محليًا وأعمال الإبداع والألعاب. NVIDIA بتذكر تكوينات بذاكرة موحّدة تصل إلى 128GB وقدرة حوسبة AI تصل إلى بيتافلوب واحد وفق معيار FP4. وفي العرض ده، قالت NVIDIA إن وكلاء الذكاء الاصطناعي على RTX Spark ساعدوا في تنسيق أجزاء من سير عمل تدريب Microduck.
فكّر في الجهاز على إنه كمبيوتر تطوير لتشغيل أدوات الذكاء الاصطناعي وبرامج الروبوتات. ممكن الجهاز المحلي يشغّل وكيلًا أو يجهّز مشهدًا أو ينسّق أدوات أو يقيّم سلوكًا مقترحًا. وده مختلف عن تشغيل تدريب واسع النطاق لمحاكاة آلاف الروبوتات في السحابة، وهي مرحلة وصفها هوانج كمان أثناء الكلمة.
3. إزاي مكونات الذكاء الاصطناعي والروبوت بتشتغل مع بعض؟
ملخص NVIDIA ذكر Hermes Agent وNemotron 3.5 Bolt 74B وIsaac Lab. وفي شرح جنسن هوانج، اتكلم كمان عن استخدام Isaac Sim وOmniverse لبناء توأم رقمي للروبوت، ومحاكاة حركته وكاميراته، ثم تقييم سياسة الحركة المتعلّمة قبل نقلها للروبوت الحقيقي.
خلي كل مرحلة واضحة: وكيل الذكاء الاصطناعي يقدر يستدعي الأدوات وينسّق الشغل؛ المحاكاة بتمثل الروبوت والبيئة رقميًا؛ وسياسة الحركة المتعلّمة بتحدد الأفعال داخل نظام التحكم الخاص بها. المكونات دي ممكن تتعاون لكنها مش نفس الحاجة.
4. المحاكاة والتدريب والتشغيل الحقيقي مراحل مختلفة
| المرحلة | إيه اللي بيحصل؟ | أهميتها |
|---|---|---|
| المحاكاة | روبوت افتراضي بيتفاعل مع بيئة ممثلة رقميًا. | المطوّر يختبر مواقف كثيرة من غير ما كل تجربة تحصل فعليًا. |
| التدريب | نظام تعلم بيحسّن سياسة الحركة بالاعتماد على إعدادات التدريب والتغذية الراجعة. | المحاولات المتكررة ممكن تساعد النظام ينفذ مهمة محددة بشكل أكثر ثباتًا. |
| التقييم | اختبار السياسة المقترحة في سيناريوهات وحالات فشل مختلفة. | لازم يكون فيه دليل إن السلوك مناسب وآمن للانتقال للمرحلة التالية. |
| التشغيل الحقيقي | نقل السياسة التي تم التحقق منها إلى الروبوت واختبارها على الجهاز الفعلي. | الأسطح والحساسات والتوقيت والحدود الميكانيكية ممكن تختلف عن المحاكاة. |
المحاكاة ممكن تسرّع التطوير، لكنها مش ضمان للأداء المثالي في الواقع. الاختلاف بين الفيزياء الافتراضية والحقيقية، وتشويش الحساسات، واختلافات الأجهزة والعوائق غير المتوقعة كلها عوامل مؤثرة. سير العمل الجيد لازم يشمل التقييم والاختبار الواقعي بدل اعتبار عرض ناجح واحد دليلًا على إن كل الحالات هتنجح.
5. ده معناه إيه لمهتمي الكمبيوتر ومطوري الذكاء الاصطناعي؟
الاتجاه الأوسع إن أجهزة الكمبيوتر المحلية بقت مفيدة في مجالات تتجاوز الألعاب وأعمال الإبداع المعتادة. المطور ممكن يشغّل نماذج لغوية ووكلاء وأدوات تطوير على جهازه، ويرجع لموارد السحابة لما المهمة تحتاج قدرة حوسبة أكبر. الاختيار المناسب بيعتمد على الخصوصية وحجم النموذج والأداء المطلوب والطاقة وتوافق البرامج والميزانية.
قرار شراء RTX Spark مختلف عن شراء جهاز ألعاب GeForce عادي. فيه مستخدمين أولويتهم فريمات عالية في الألعاب، وفيه مطورين محتاجين ذاكرة أكبر أو منظومة برامج AI مدعومة أو أدوات Workstation وسحابة. اختار الجهاز بناءً على التطبيقات والمتطلبات اللي هتستخدمها فعلًا، مش بناءً على مقطع روبوت مثير فقط.
للتجميعات المكتبية العادية، تقدر ترجع إلى أدلة المؤسسة الفرنسية للكمبيوتر لفهم متطلبات تشغيل الذكاء الاصطناعي محليًا واختيار الباور سبلاي المناسب لكارت الشاشة. دي أدلة عامة لاختيار مكونات الكمبيوتر، مش ادعاء إن كارت الألعاب يعادل RTX Spark.
6. إجابات سريعة
هل جنسن طلب فعلًا من الروبوتات إنها تاخد قيلولة؟
أيوه. خلال كلمة GTC Berlin يوم 21 أكتوبر، طلب من Microducks إنها تقعد وتقوم وتاخد قيلولة. وReuters ذكرت الاستجابة غير المتساوية وطلب الشقلبة بعد كده.
هل RTX Spark نفّذ كل تدريب الروبوت؟
ما ينفعش نقول كده. NVIDIA بتقول إن وكلاء شغالين على RTX Spark استخدموا ضمن سير عمل التدريب. وشرح هوانج كمان تدريب آلاف النسخ الافتراضية في السحابة، ثم تنزيل سياسة الحركة وتقييمها قبل نقلها للروبوت الحقيقي.
إيه هو Isaac Lab؟
Isaac Lab إطار عمل مفتوح المصدر من NVIDIA لتعلم الروبوتات وسير عمل المحاكاة. هو جزء من برمجيات تطوير الروبوت، ومختلف عن جهاز الكمبيوتر نفسه.
هل كمبيوتر ألعاب عادي يقدر يدرّب روبوت بنفس الطريقة؟
ده بيعتمد على البرنامج والمهمة والنموذج والذاكرة ودعم كارت الشاشة وحجم التدريب. كمبيوتر الألعاب ممكن يكون مفيد لبعض تجارب AI، لكن لازم تتراجع المتطلبات قبل افتراض إنه يقدر ينفذ سير العمل الكامل ده.
المصادر وقراءة إضافية
- مدونة NVIDIA — ملخص RTX Spark وMicroduck (21 أكتوبر 2026)
- NVIDIA — ملخص الكلمة الرئيسية في GTC Berlin 2026
- التوثيق الرسمي لـ NVIDIA Isaac Lab
- Pollen Robotics — صفحة Microduck الرسمية
- كلمة NVIDIA في GTC Berlin — تفاصيل الحدث والفيديو